BIM-Guided Robotic Alignment
We enable construction robotic learning to align components with building information model (BIM) by projecting digital designs directly onto physical workfaces.
01 / THE PROBLEM & RATIONALE
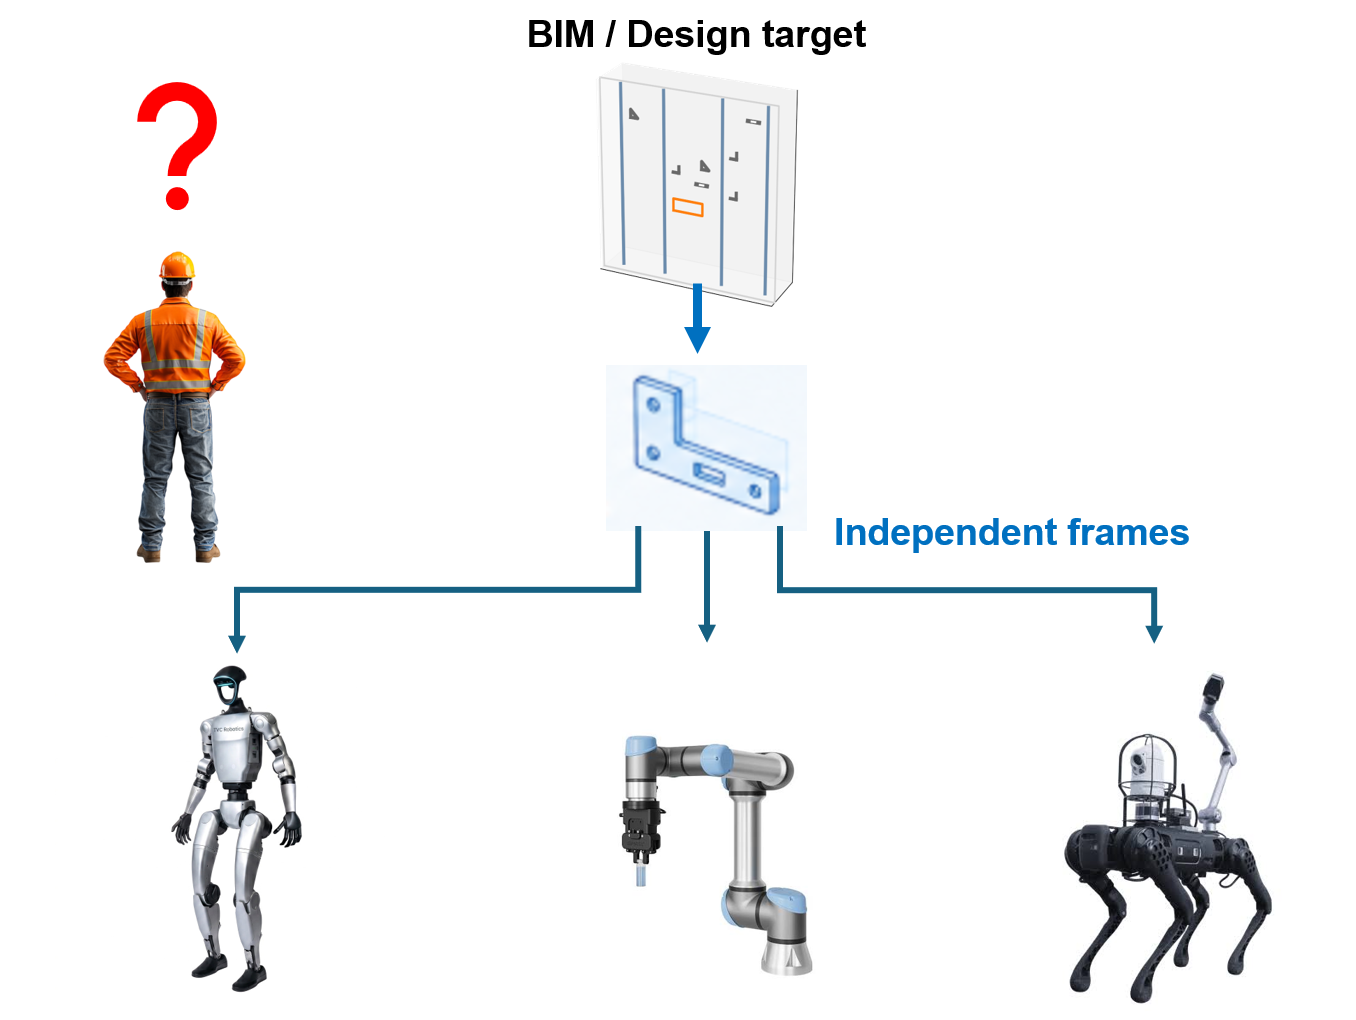
BIM Designs Are Not Directly Actionable Across Different Robots
OUR RATIONALE
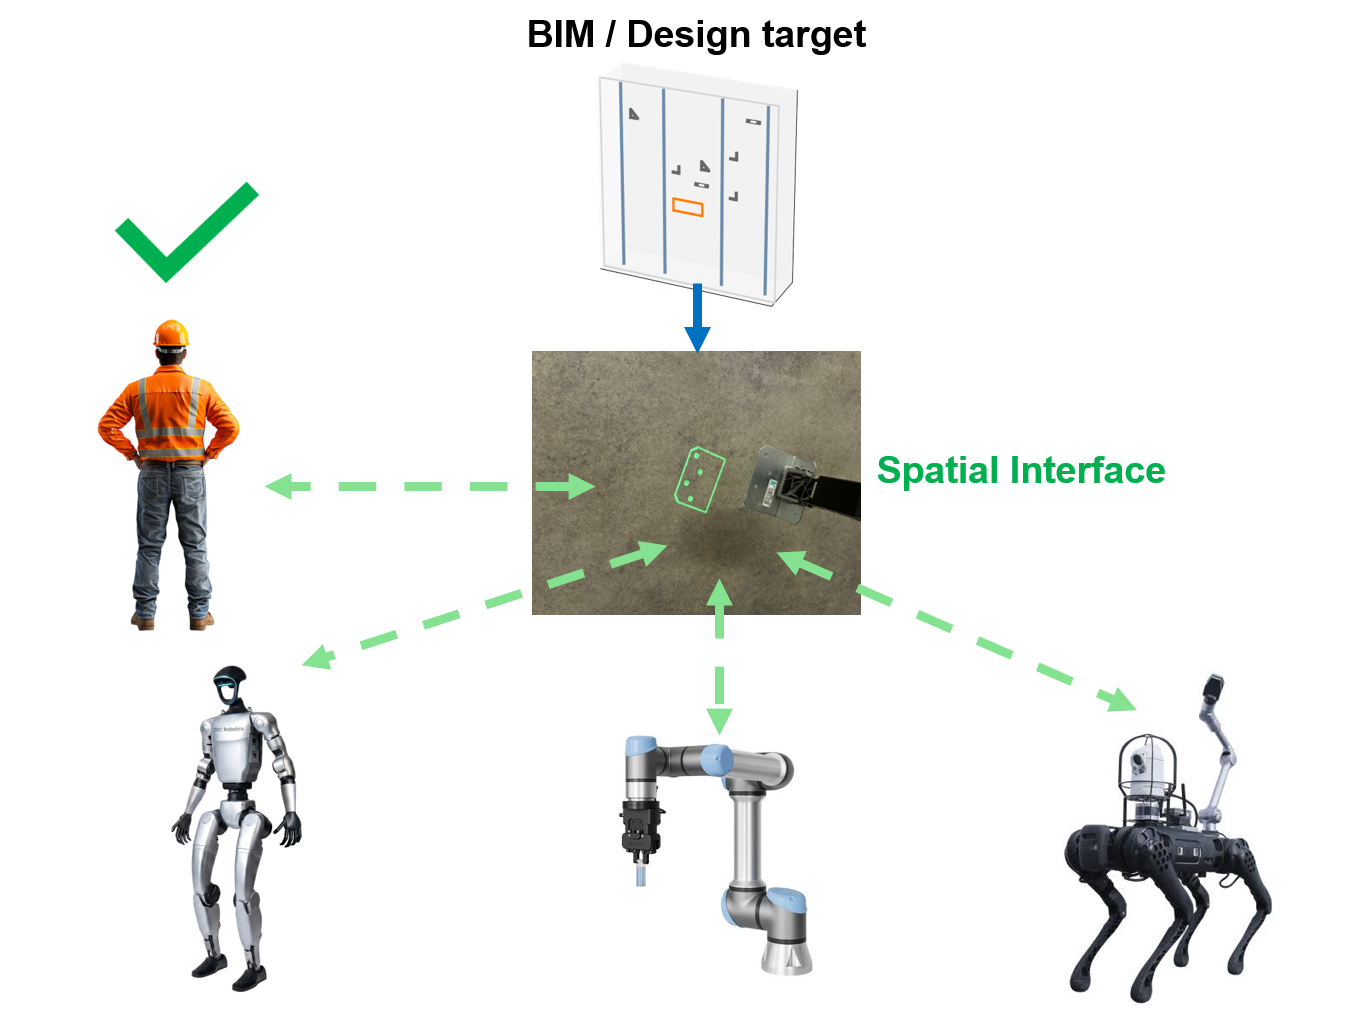
Project BIM-defined targets onto the workface to enable:
Visible Targets
Robots see where to build.
Learning-Based Alignment
Robots learn to align using visual feedback.
Shared Reference
Different robots and workers can use the same targets.
02 / METHOD
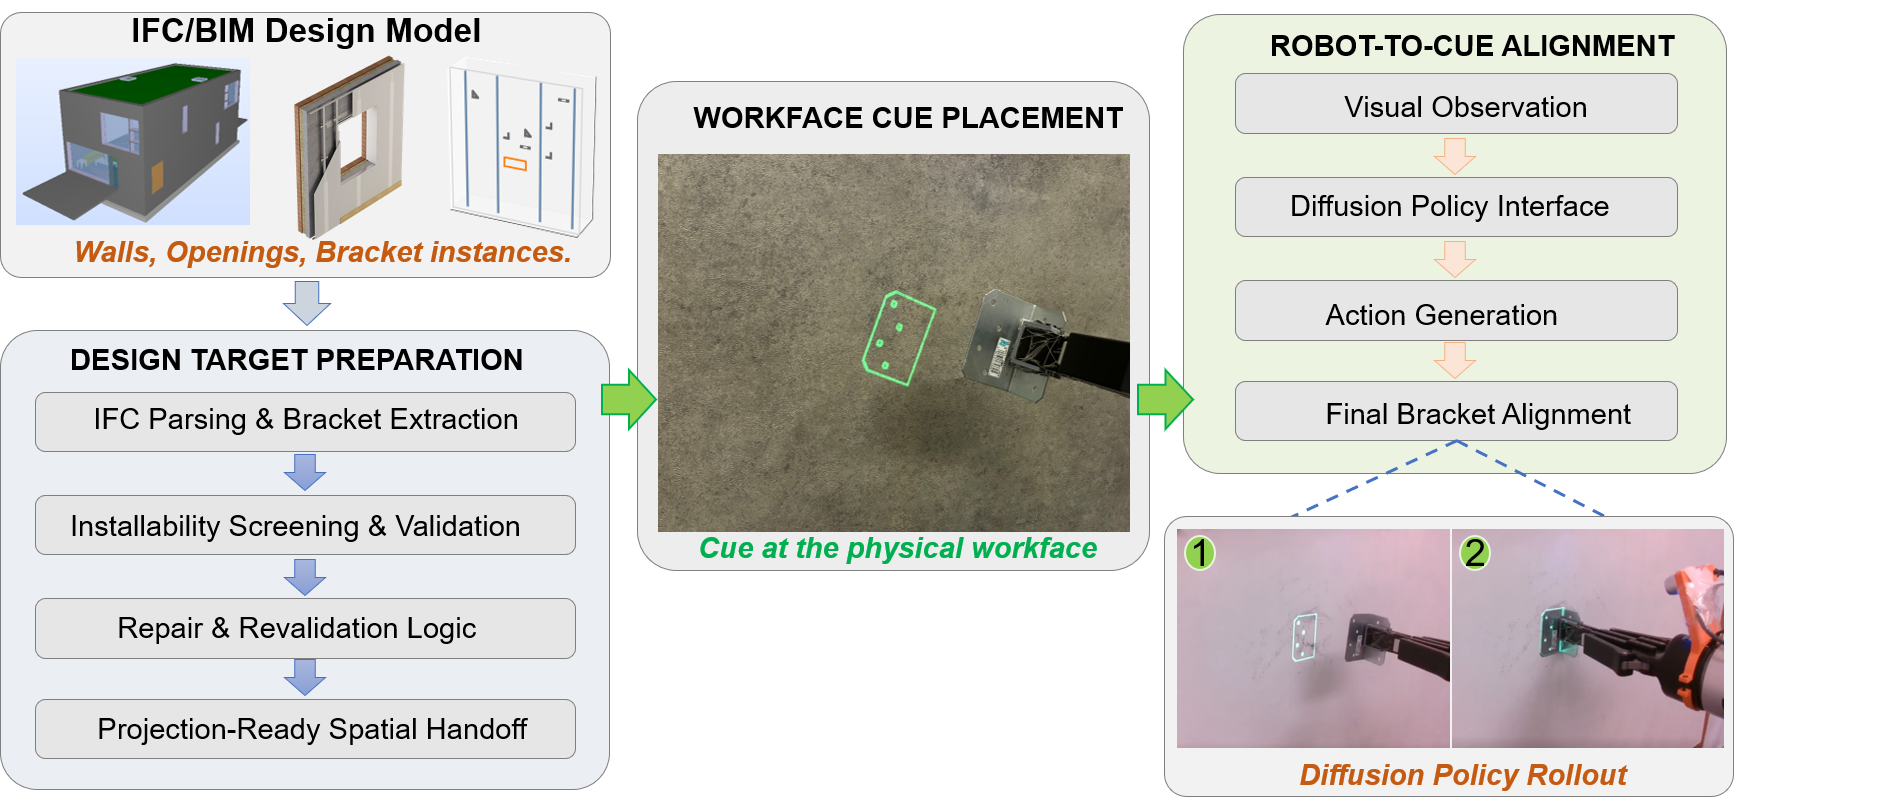
From BIM to Robotic Alignment
We extract construction plans from BIM, project them onto the workface, and use a learned vision-based policy for robots to align construction components.
03 / PERFORMANCE
Robotic Alignment in Action
The robot aligns brackets with projected BIM targets across three wall appearances using visual feedback.
2× speed
6× speed
6× speed
Ready when visible
- Success Rate
- 80.7%
- Mean In-Plane Error
- 1.65 mm
- Trials
- 135