Dull
73%
of roofers make repetitive motions continually or almost continually.
Source ↗A silent film of three shots at original speed, shown beside the robot. On an unfinished pitched roof, a worker carries a sheet of sheathing across the slope, bends over it with a handheld tool, and lowers into a deep crouch with both feet on the slope. Timber framing, neighboring houses, trees and sky are in view. This is field footage recorded by the research team.
A silent film of two shots at original speed, shown beside the roofer. In a laboratory, a Unitree G1 humanoid on a padded incline bends and lowers a handheld tool toward the pad, and in a separate trial bends deeply toward the surface. A safety tether is attached. The frame is cropped to follow the robot; the operator holding the controller stands just outside it. The robot shots end before later motion, falls, or resets and do not show fastening.
73%
of roofers make repetitive motions continually or almost continually.
Source ↗97%
of roofers work outdoors, exposed to all weather conditions, every day.
Source ↗48.7
fatal work injuries per 100,000 full-time-equivalent roofers in 2024, against 3.3 for all workers.
Source ↗41%
of U.S. single-family home builders report a shortage of roofing subcontractors, in a September 2026 survey.
Source ↗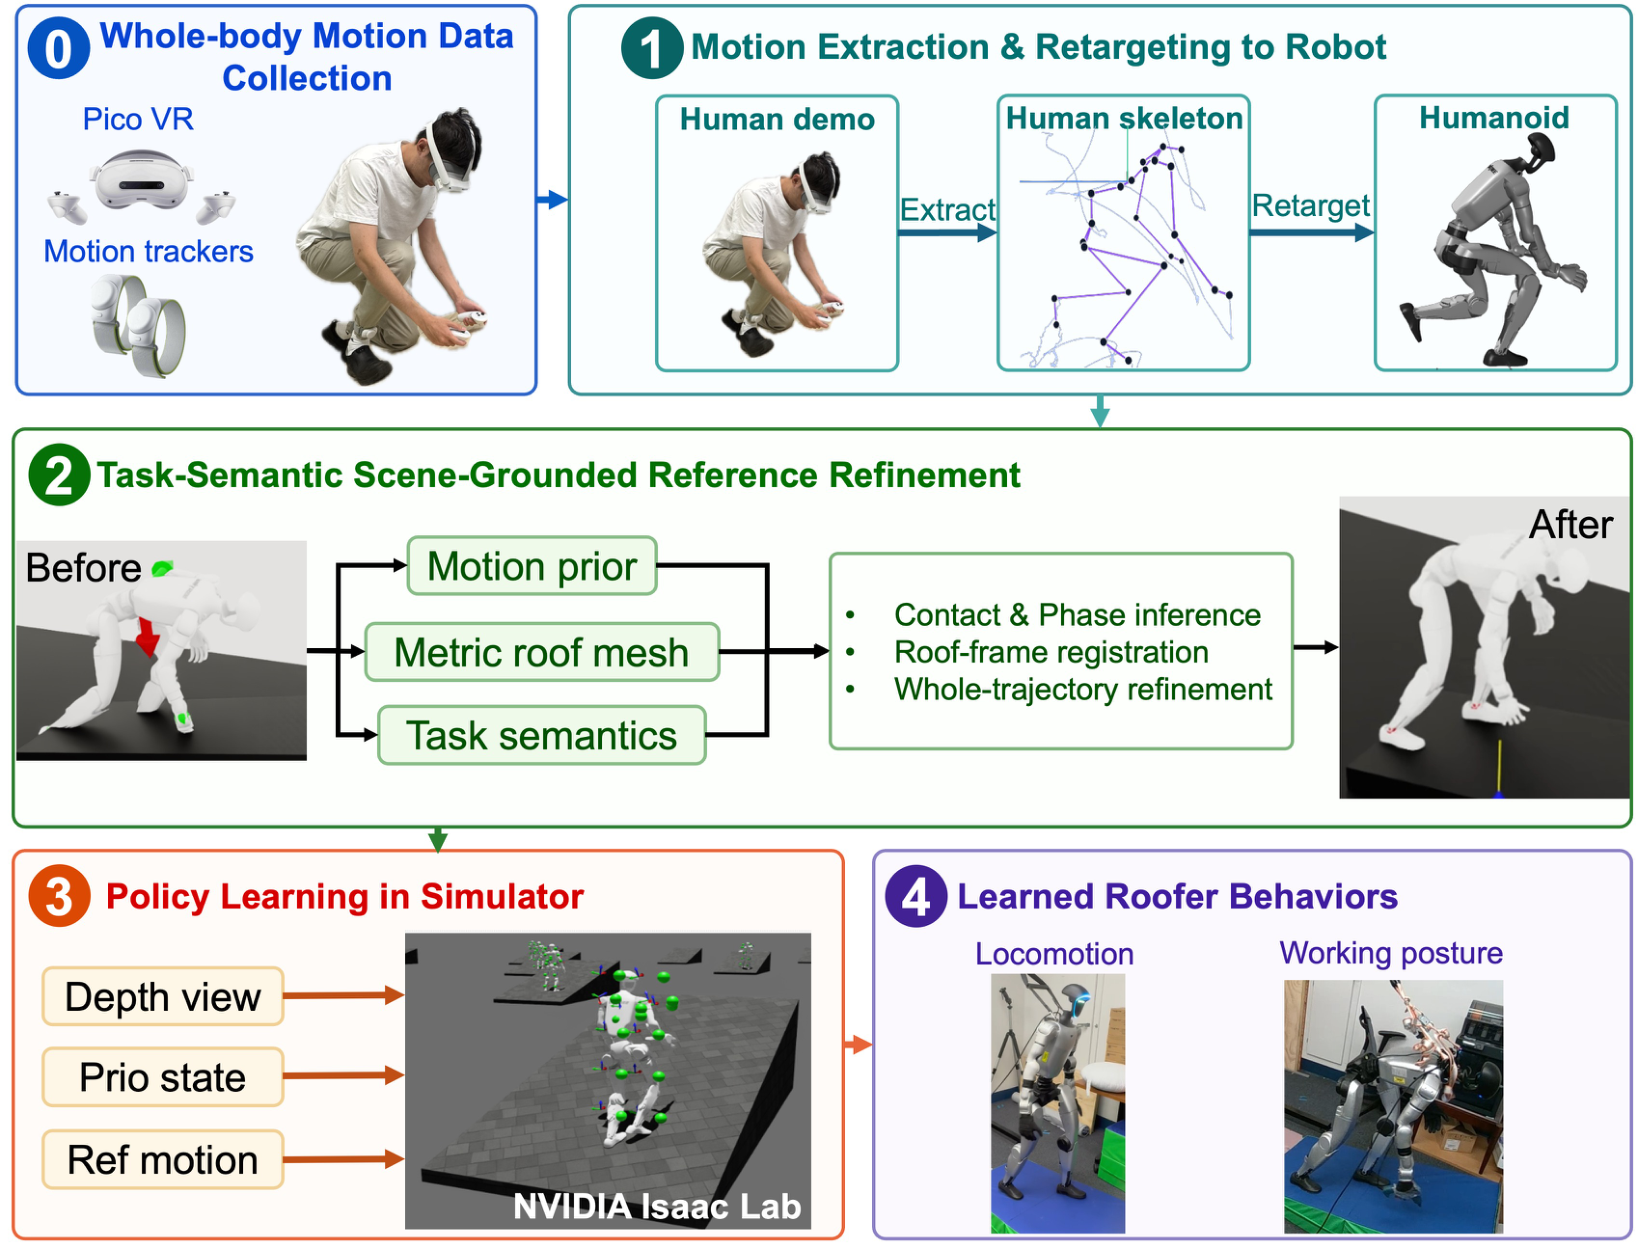
Figure panel 0Motion capture. PICO VR tracking records a person performing roofing motions.
Figure panel 1Motion retargeting. The human motion is extracted and retargeted to the Unitree G1.
Figure panel 2Reference refinement. A metric roof mesh sets foot support and task-specific hand clearance across the whole trajectory.
Figure panel 3Policy learning in simulation. Reinforcement learning tracks the refined reference. Extra rewards hold hand clearance and prevent hand-mesh penetration.
Figure panel 4Physical tests. Uphill walking, nailgun positioning, hammering, and bending on a slope, with a safety hoist attached.
Left, a roofer carries a sheet of sheathing up a pitched roof. Right, a Unitree G1 humanoid walks from the floor onto a padded incline. The two halves come from separate recordings shown side by side, so their motions are not synchronized. The roofer footage is mirrored so both face the same way. The robot is in a laboratory with an overhead safety tether attached, and the frame is cropped so the operator holding the controller stands just outside it. The robot excerpt ends before later motion, falls, or resets and does not show fastening. Silent, at original speed.
Left, a roofer stands at the roof edge and bends down to reach a sheet of sheathing passed up from below. Right, a Unitree G1 humanoid bends deeply toward a padded incline. The two halves come from separate recordings shown side by side, so their motions are not synchronized. The roofer footage is mirrored so both face the same way. The robot is in a laboratory with an overhead safety tether attached, and the frame is cropped so the operator holding the controller stands just outside it. The robot excerpt ends before later motion, falls, or resets and does not show fastening. Silent, at original speed.
Left, a roofer bends over the sheathing with a pneumatic nailer close to the surface. Right, a Unitree G1 humanoid steps forward on a padded incline, bends, and lowers a handheld tool toward the pad. The two halves come from separate recordings shown side by side, so their motions are not synchronized. The roofer footage is mirrored so both face the same way. The robot is in a laboratory with an overhead safety tether attached, and the frame is cropped so the operator holding the controller stands just outside it. The robot excerpt ends before later motion, falls, or resets and does not show fastening. Silent, at original speed.
Left, a roofer takes a hammer from the tool belt, bends over the sheathing, and strikes near its edge. Right, a Unitree G1 humanoid steps forward and bends deeply, bringing its hand and tool close to the padded surface. The two halves come from separate recordings shown side by side, so their motions are not synchronized. The roofer footage is mirrored so both face the same way. The robot is in a laboratory with an overhead safety tether attached, and the frame is cropped so the operator holding the controller stands just outside it. The robot excerpt ends before later motion, falls, or resets and does not show fastening. Silent, at original speed.
Songyang Liu, Shuai Li. Learning Slope-Adaptive Whole-Body Locomotion for Humanoid Robots in Roofing Construction. arXiv:2609.20558v1, submitted 17 September 2026.DOI: 10.48550/arXiv.2609.20558.
@misc{liu2026roofing,
  title = {Learning Slope-Adaptive Whole-Body Locomotion for Humanoid Robots in Roofing Construction},
  author = {Songyang Liu and Shuai Li},
  year = {2026},
  eprint = {2609.20558},
  archivePrefix = {arXiv},
  primaryClass = {cs.RO},
  doi = {10.48550/arXiv.2609.20558},
  url = {https://arxiv.org/abs/2609.20558v1}
}
Accessibility & media credits · Website source · Template: Roman Hauksson